
- High-Performance Doors
-
- Applications
-
-
-
- Clean Room
Stainless steel or composite materials help maintain clean rooms.
-
-
- Coolers
Quick opening speeds & tight seals for temperature control.
-
-
- Parking
Improve security & traffic flow and enhance architectural style.
-
-
- Hurricane Zone
Withstand winds up to 175 mph and comply with the Florida Building Code.
-
-
-
-
- USDA / FDA / cGMP
Increase productivity & address stringent USDA, FDA & cGMP requirements.
-
-
- Freezers
High-speed & perimeter seals minimize the air exchange between areas.
-
-
- Security
High speed & durability ensure secure access.
-
-
- Ventilation
Perforated or screen door panels allow improved air circulation.
-
-
-
-
- Fire Station Emergency Response
When time is of the essence, high speed and reliability are crucial.
-
-
- Warehousing
Fast cycle times and secure seals keep environments separated.
-
-
- Loading Dock
Rugged design & secure seal for oversized openings.
-
-
- Large Openings
Break-away functionality with rugged design seals oversized openings.
-
-
-
-
- Heavy Equipment
Withstands challenges of heavy equipment and fleet truck/car wash environments.
-
-
- Self-Storage
Fast opening speeds and reliable, durable construction keep facilities secure and protected.
-
-
- Industries
-
-
-
- Automotive Dealerships
Reduce energy costs, increase productivity and comfort and enhance customer perception.
-
-
- Cold Storage & Processing
Increase productivity and operational efficiency while reducing energy and maintenance costs.
-
-
- Parking
We offer solutions for Apartment / Condo & Loft, Standalone Parking Facilities and Office Buildings
-
-
-
-
- Food & Beverage
Doors specifically engineered for USDA/FDA and cGMP environments, and assured compliance for uncompromising performance.
-
-
- Mfg/Dist/Warehousing
A complete product line allows facilities to increase efficiency and safety and reduce maintenance and energy costs.
-
-
- Government
Ensure effective security and environmental controls are maintained for critical government operations.
-
-
-
-
- Transit
Keep operations running smoothly and efficient while reducing energy and maintenance costs.
-
-
- Pharma, Nutraceutical & Biotech
Doors that offer quick, secure access, environmental control and reliability for life science facilities.
-
-
- Support Resources
- Parts
- Contact Us
- Blog/News
- Why Rytec
- Sales Rep Locator
- Careers
- Dealers
- Architectural Resources








China Top Rotary Actuator Symbol Guide for Global Buyers
For global buyers, a Rotary Actuator Symbol is more than a small drawing on a hydraulic or pneumatic schematic. It identifies movement, energy flow, control logic, and connection points before anyone opens the equipment crate. In Chinese manufacturing markets, accurate symbol reading can prevent costly misunderstandings between engineers, suppliers, and maintenance teams.
Peter Nachtwey, a respected motion-control and hydraulics specialist, offers a practical reminder: “A symbol must communicate function before it communicates detail.” This principle matters when comparing rack-and-pinion actuators, vane actuators, and electric rotary units. A familiar circle, arrow, or port mark may look simple. Its meaning can change with the drawing standard and application.
This guide examines how Chinese manufacturers present the Rotary Actuator Symbol in catalogs, CAD files, quotations, and technical diagrams. It also connects symbols with real details, such as shaft rotation, torque direction, working pressure, port arrangement, and end-stop control. ISO 1219 conventions provide a useful reference, but supplier documents still require careful review. Not every catalog is equally clear.
Look closely.
A missing arrow can create doubt. An unclear port label can delay installation. Even experienced buyers may overlook these details when specifications appear attractive. This guide therefore encourages practical verification, not blind reliance on a symbol alone. Ask for the model drawing, operating data, and confirmed symbol interpretation before approval. The process is not flawless, and some diagrams remain open to interpretation. That is precisely why informed comparison remains essential for reliable international purchasing.
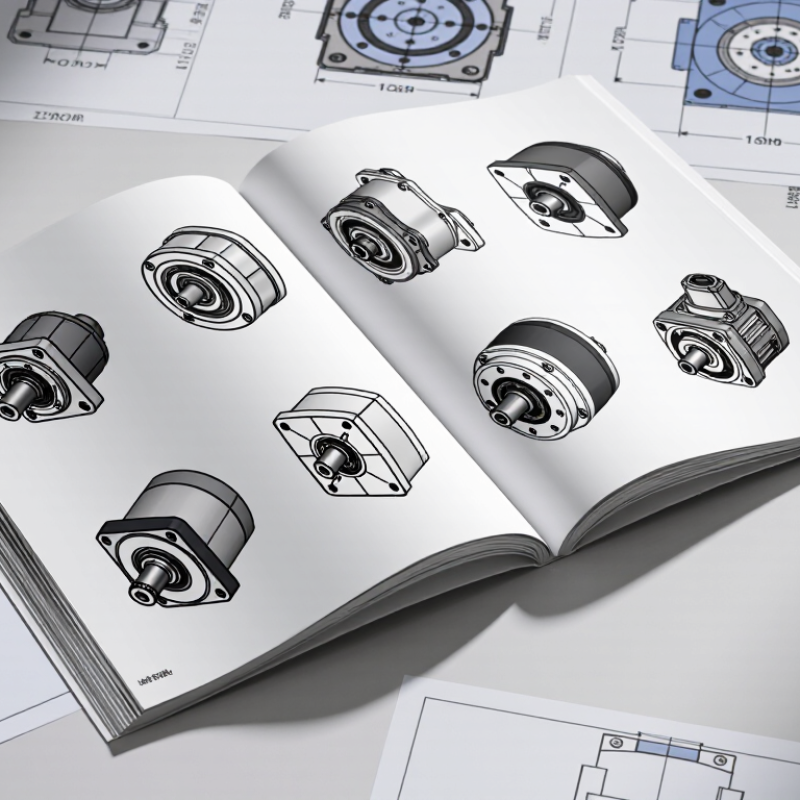
Table of Contents [Hide]
Defining Rotary Actuator Symbols Under ISO 1219-1:2012 and GB/T 786.1
For global buyers, rotary actuator symbols are more than drawing shortcuts. They define function, motion, and connection logic. ISO 1219-1:2012 provides the international framework for fluid power symbols. GB/T 786.1 supports the corresponding technical language used in Chinese documentation. Reading both carefully reduces translation errors during sourcing and design reviews.
A rotary actuator symbol commonly shows a circular body with an arrow indicating rotary movement. Port lines reveal the working connections. Additional marks may indicate the operating principle or control arrangement. However, the symbol does not state torque, rotation speed, shaft material, or sealing performance. These details belong in the specification sheet.
Look closely at the arrow direction. It can expose a mismatch between the requested rotation and the proposed circuit. Check the number and position of ports against the actual drawing. Simple checks matter. In my experience reviewing hydraulic and pneumatic diagrams, buyers sometimes approve symbols without checking the legend. That is a weak habit, and standards alone cannot correct it. A reliable purchase review should compare ISO 1219-1:2012 and GB/T 786.1 references, then confirm pressure, torque, angle, mounting, and fail-position data separately. Some diagrams remain open to interpretation. Ask for clarification before production.